Hello! 😊
This is Yiran Huang, a senior in Mechanical Engineering with a concentration in robotics at Northwestern. This is my portfolio recording some of the most fun projects about robotics that I have been a part of.
Hope to connect with you or simply discuss any of the following!
Educations
 |
Northwestern University 2022.09 - 2026.06 B.S. with honors in Robotics/Mechanical Engineering, GPA: 3.93 |
Research
|
Northwestern University Haptics Lab 2024.09 - Present Undergraduate Reseaerch Assistant (Advised by Professor J. Edward Colgate) |
|
Northwestern University Advanced Manufacturing Processes Lab 2024.02 - 2024.9 Undergraduate Reseaerch Assistant |
Projects
Dextorous Manipulation, Actuation
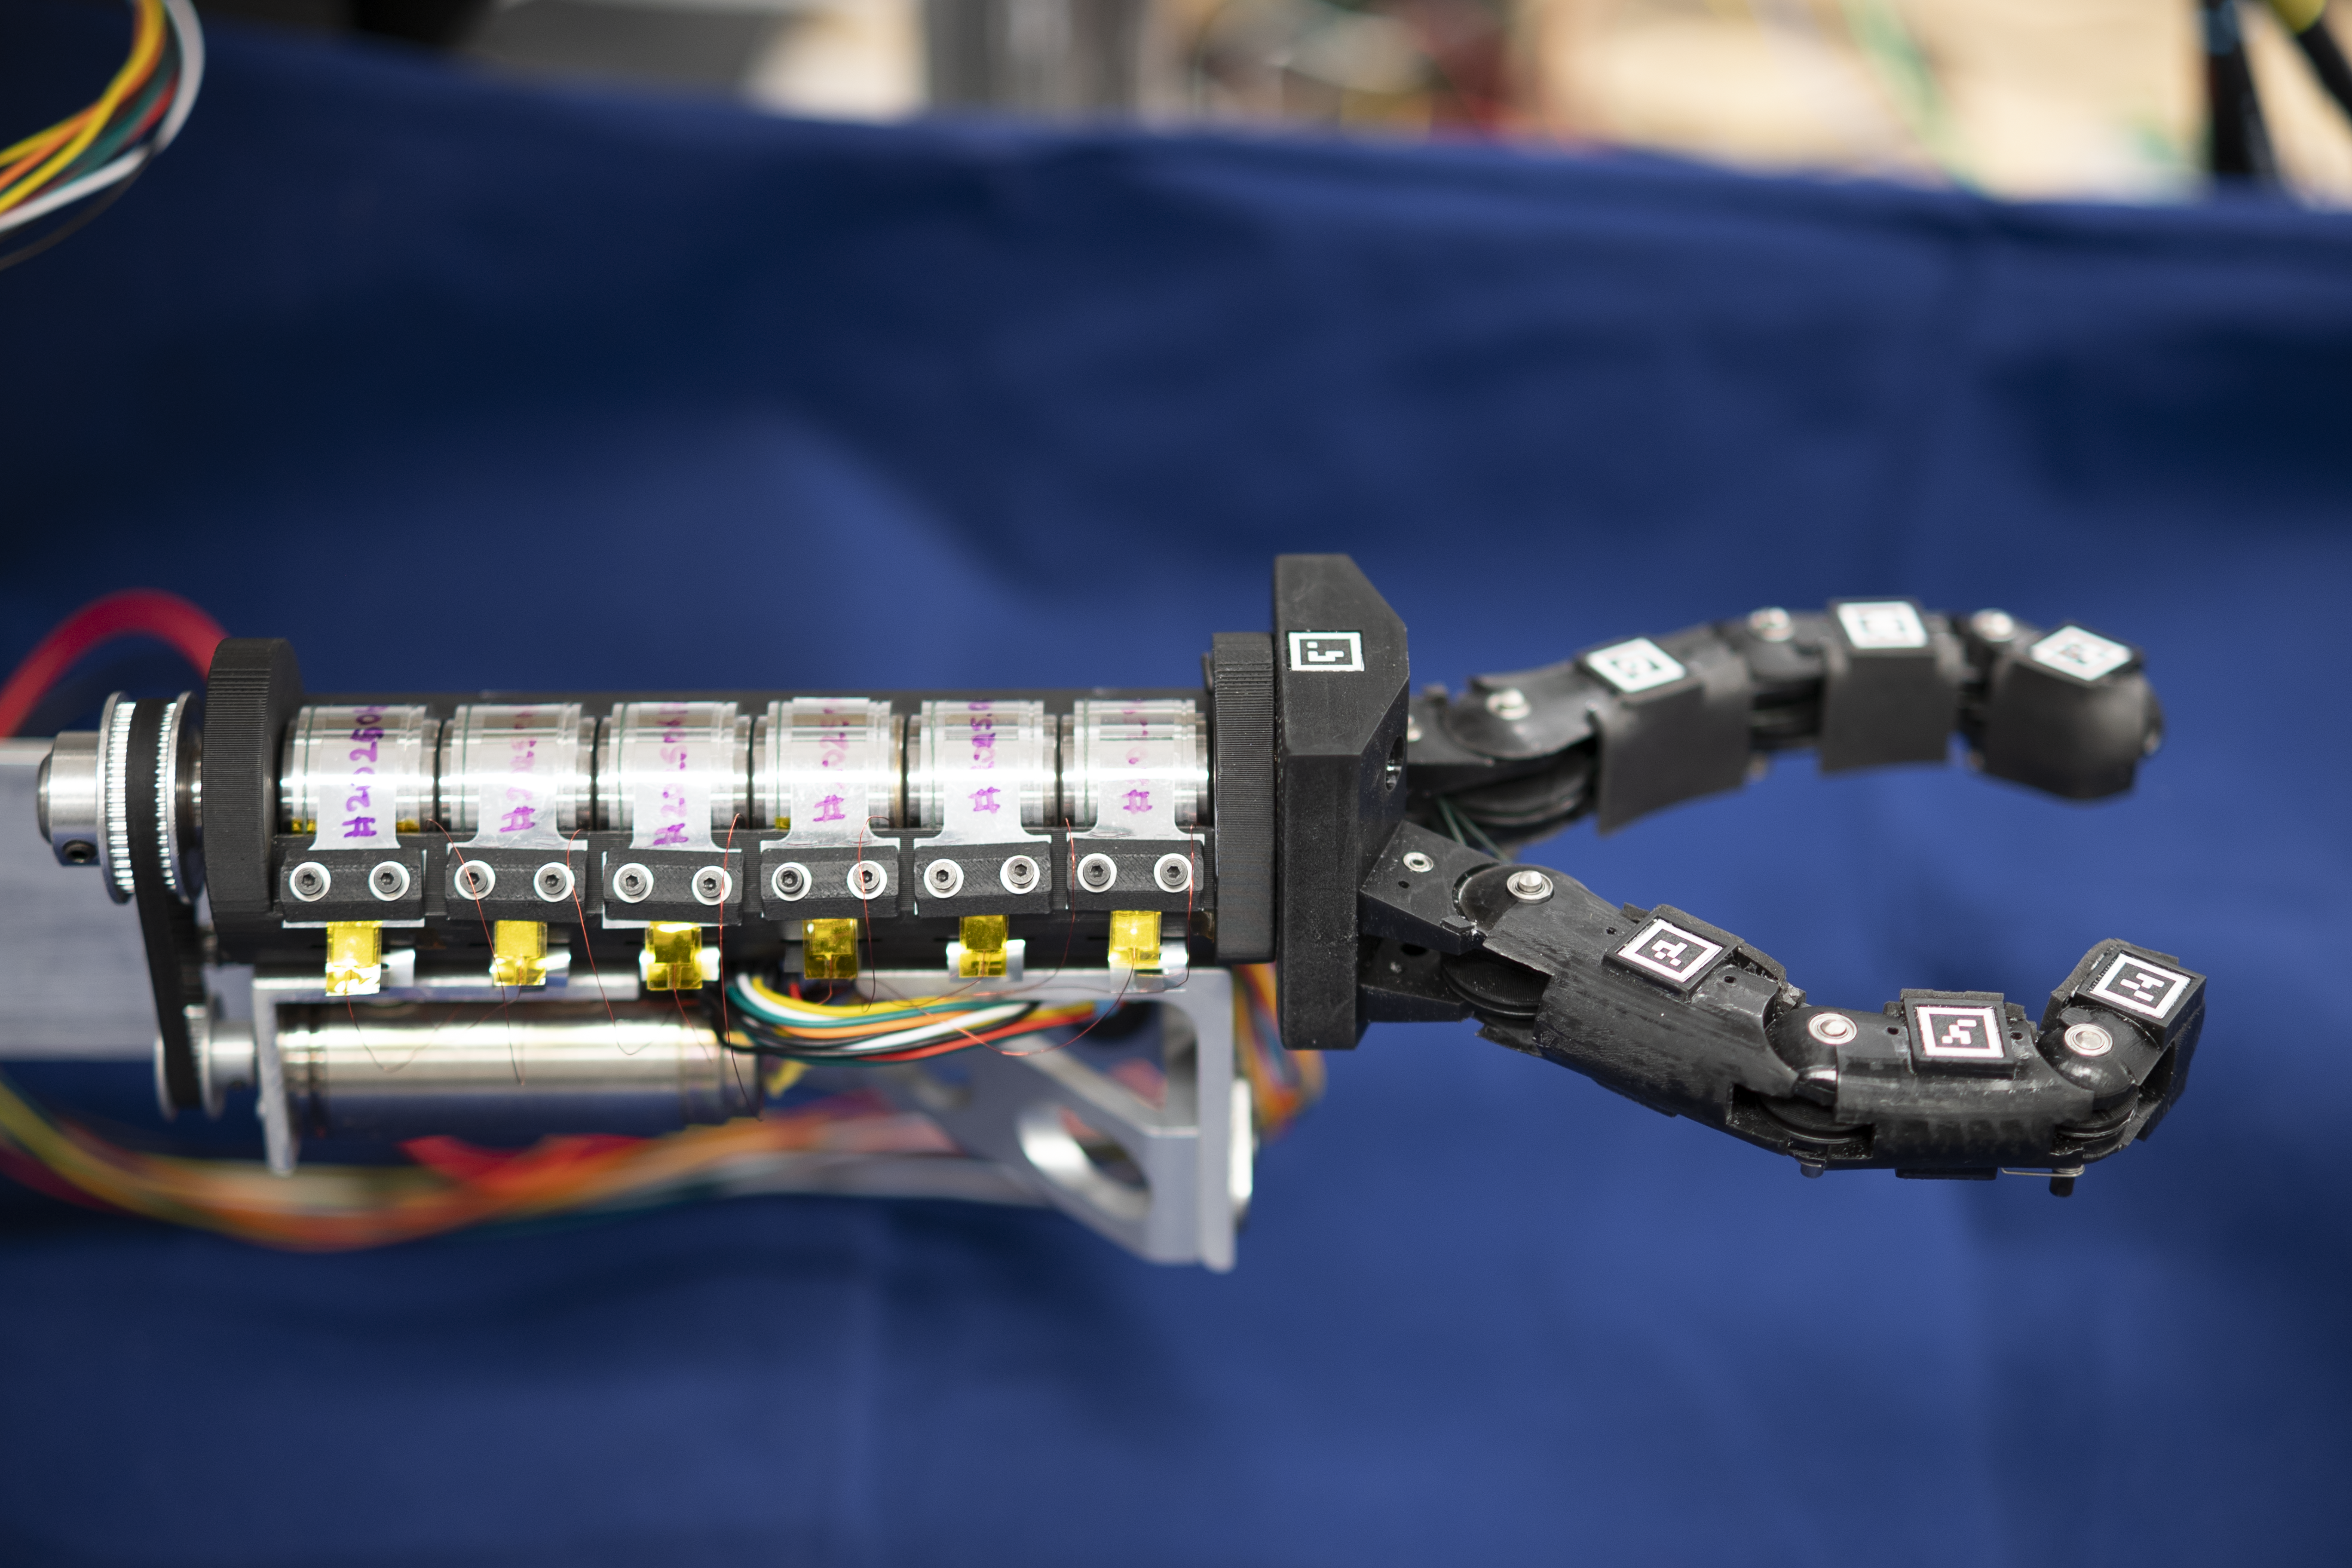
Electroadhesive Multiplexer [Arduino, SolidWorks, Rapid Protyping]
- Designing a compact magnetic-encoder–based angular sensing module for real-time joint motion tracking, supporting clutch state estimation and tendon position measurement
- Building a coordinated clutch-switching and motor-drive control software for the EA multiplexer for both velocity and force control
- Conducting experiments to measure braking force and response time of the clutches under the EA multiplexer, as previous experiments are only done on testbeds.
Soft Robotics Control
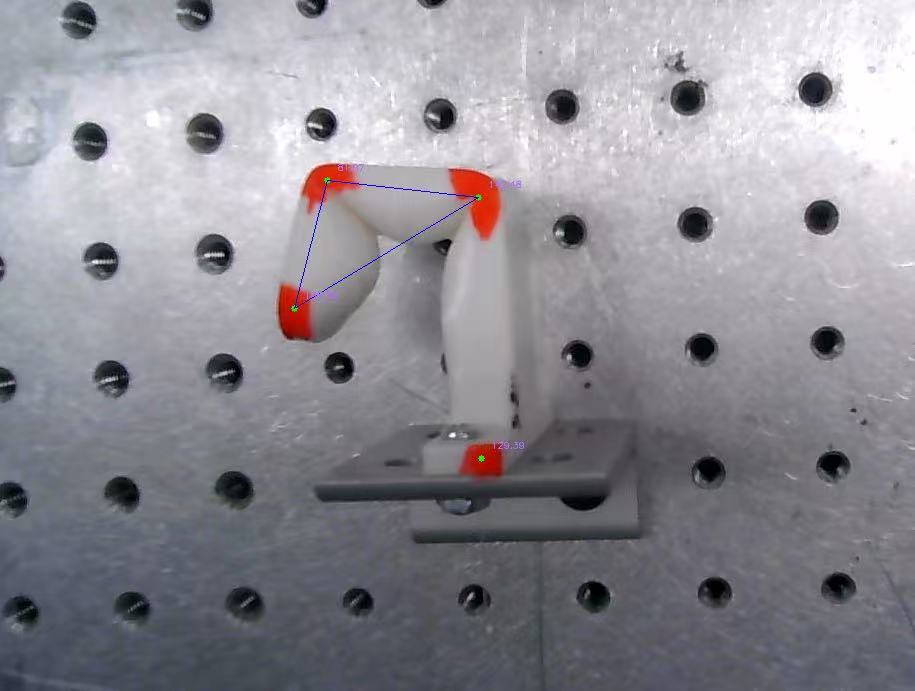
Control of Soft Robotic Hand [Arduino, Additve Manufacturing]
- Designed and manufactured soft tendon-actuated fingers through additive manufacturing in collaboration with Carnegie Mellon University
- implemented a PID-based control system enabling precise tendon motion using an electroadhesive clutch for variable stiffness and braking.
Feedback Control, Kinematics
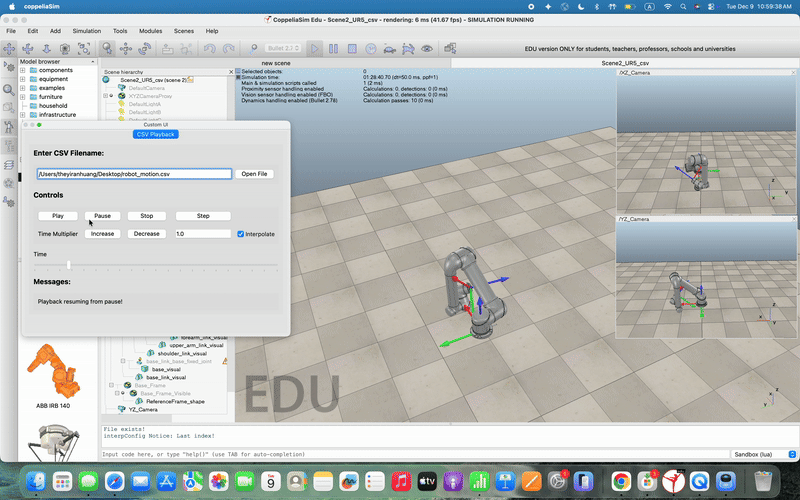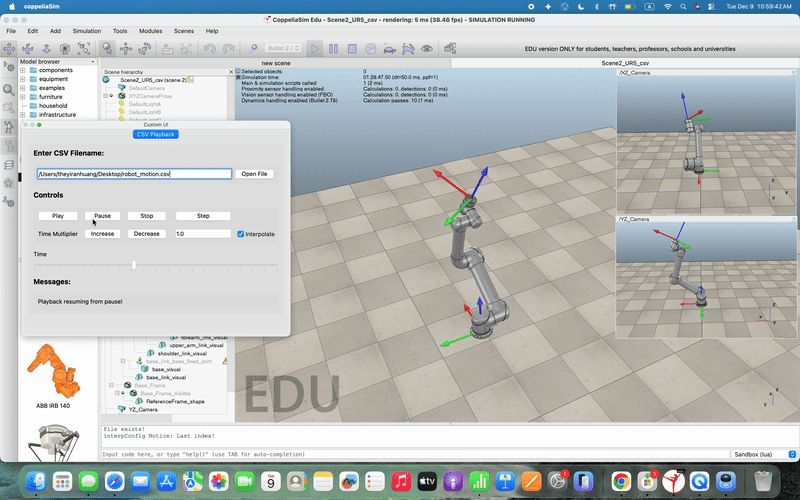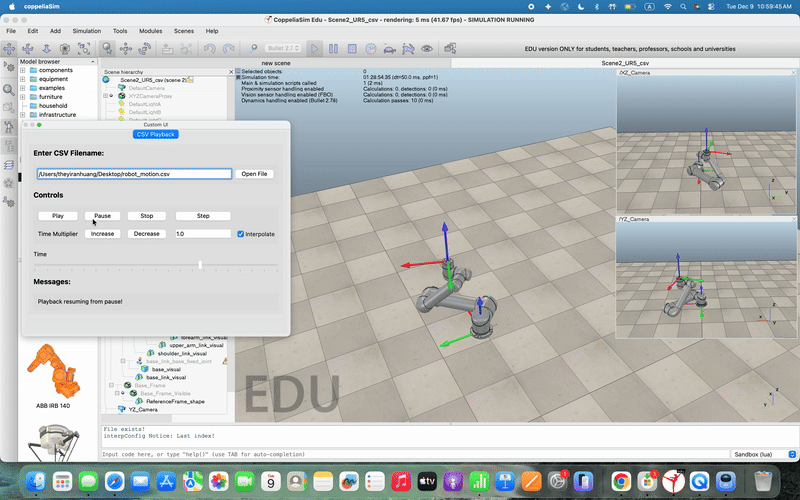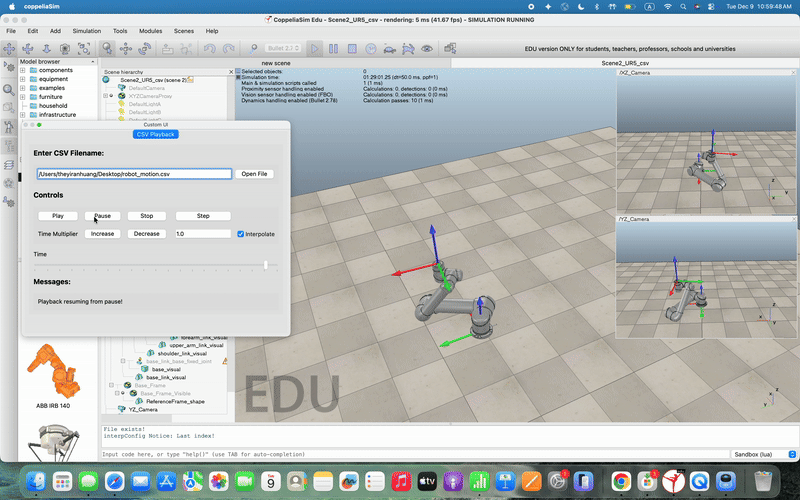
UR5 Trajectory Manipulation [Python]
- Developed a simulation for a UR5 robot arm , implementing trajectory generation via screw theory and kinematic modeling
- Constructed a PID feedback control system with pseudoinverse Jacobian for end-effector tracking while consideirng joint limit constraints and singularity handling for stable pick-and-place operations
Ergodic Control
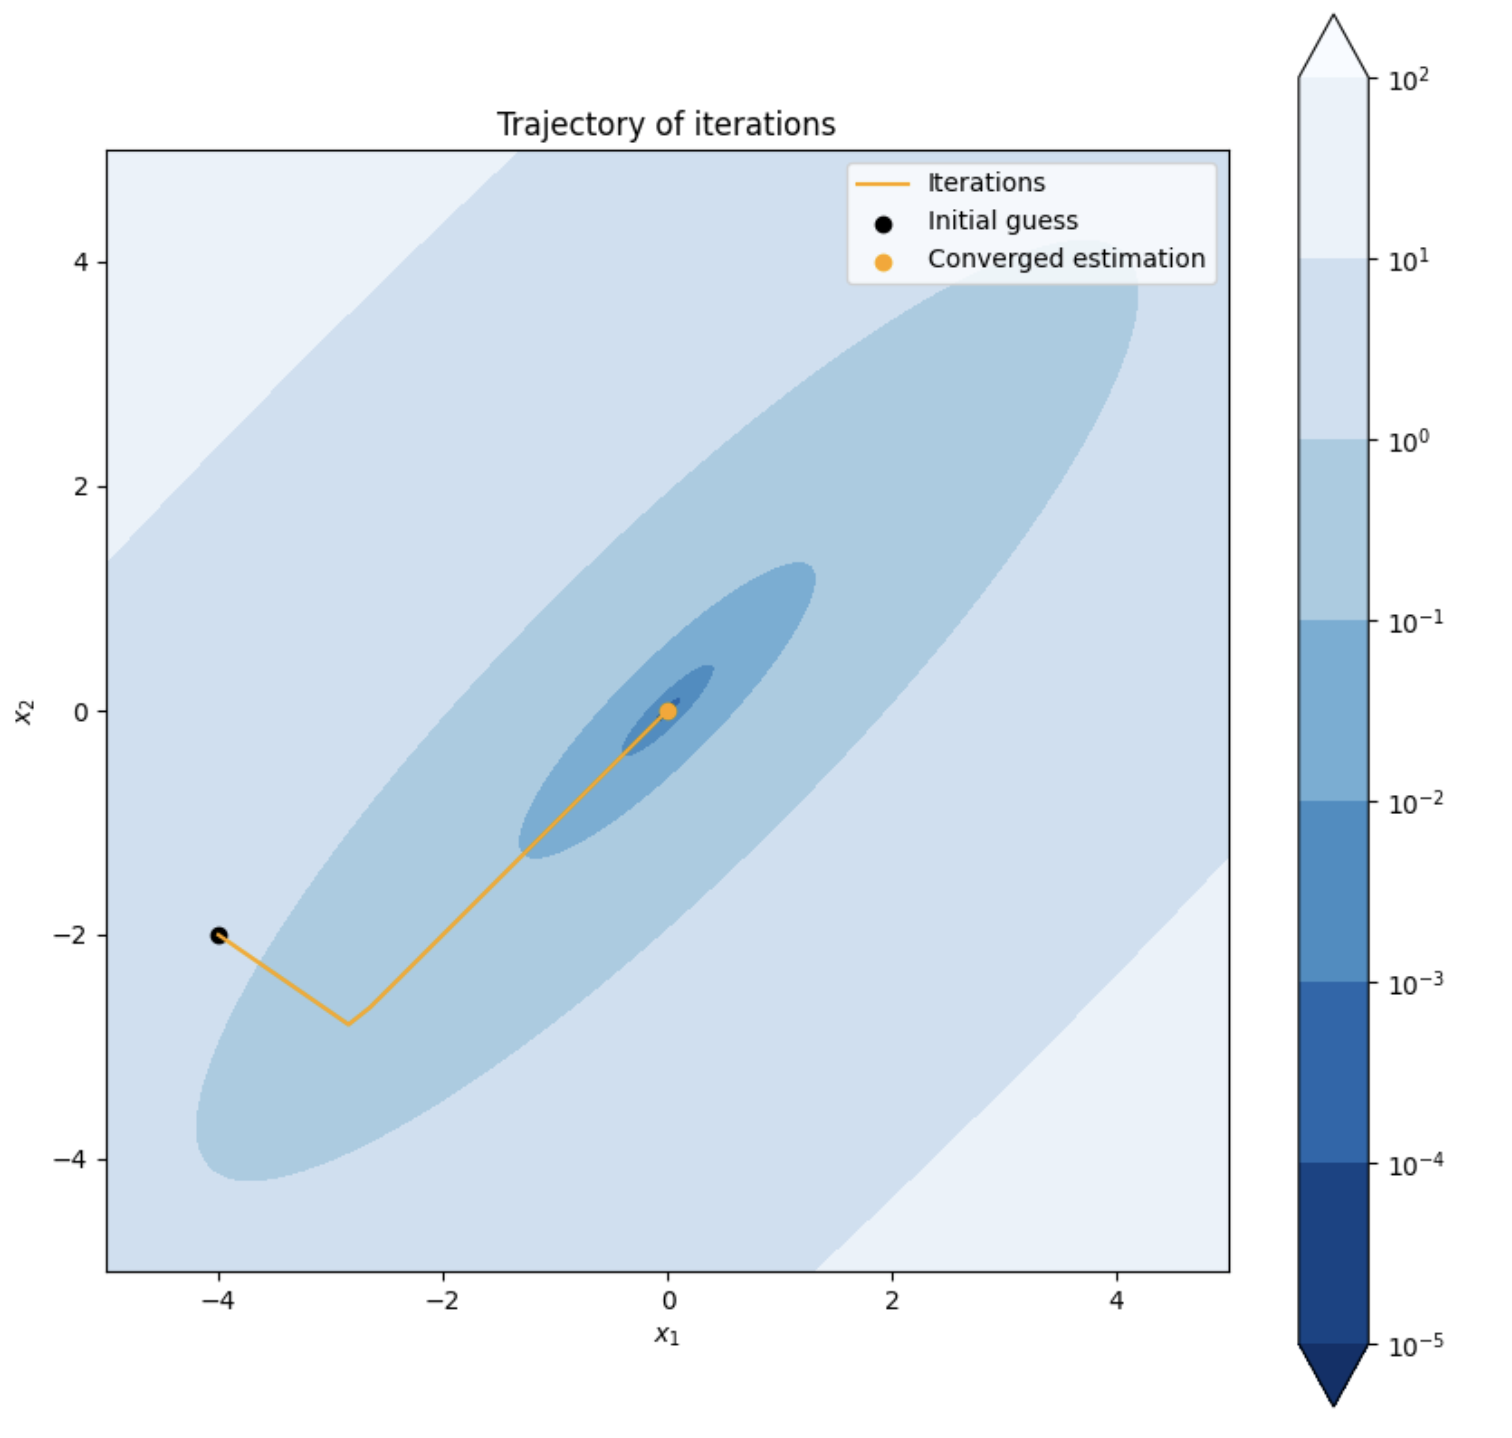
Ergodic Control for Sensor-Based Exploration [Python]
- Implemented ergodic control for a 2D single-integrator agent to optimize exploration based on spatial information density
- Developed a simulation environment and visualizations to demonstrate convergence of metrics over time
- Compared ergodic behavior to random and greedy policies to evaluate performance under sparse information distributions
Dynamic Simulation
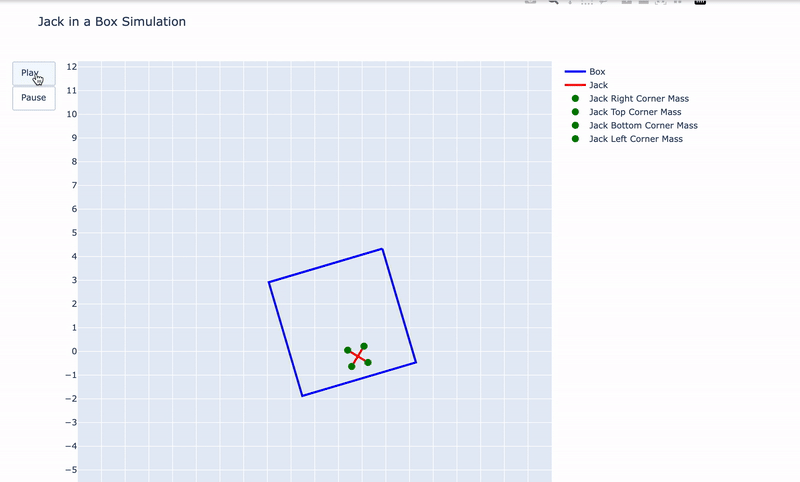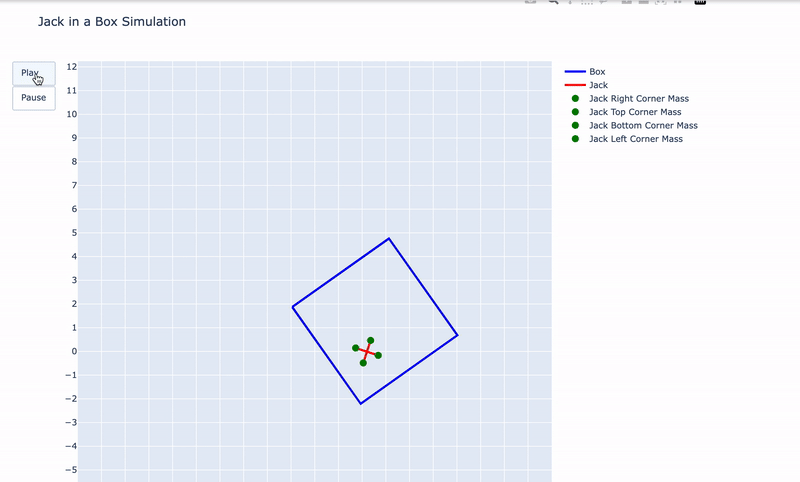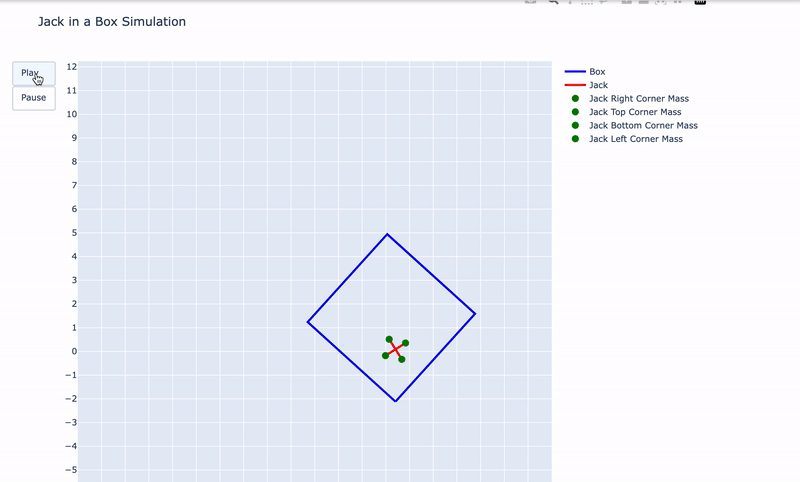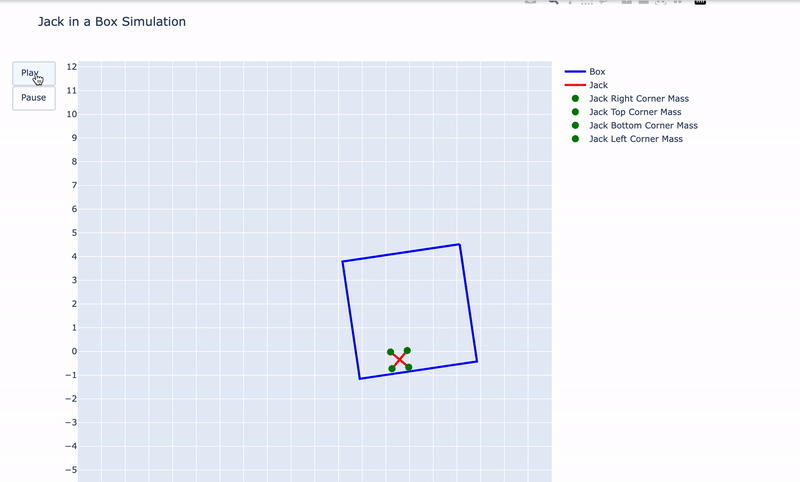
Lagrangian Dynamics Simulation of Jack in a Box [Python]
- Simulated a Jack in a Box using a 2D multibody system governed by Euler-Lagrange dynamics
- Modeled motion as a double pendulum swing with constraints and as projectile motion with plastic impact
- Used SE(2) transformation matrices to track orientation and position of rigid bodies
- Modeled plastic collisions and enforced contact constraints for realistic landing conditions
Future Work
- Ongoing: Designing a 3 DOF remotely actuated finger as senior capstone